When a multi-million-dollar automated guidance system or robotic assembly arm veers off course, engineers rarely look at high-school math for the culprit. Yet, at the heart of many silent computational bugs lies a fundamental baseline constant: sin 0. While calculating the sine of zero degrees seems mathematically trivial—yielding an exact value of zero—its mishandling in modern software architectures, floating-point arithmetic engines, and sensor calibration arrays sparks cascading logic errors. Understanding how this boundary condition breaks complex architectures is the first step toward building bulletproof operational safeguards.
The search intent behind this topic centers on engineering reliability, numerical stability, and fault injection analysis. Practitioners and software architects want to know why basic trigonometric identities cause runtime failures, how floating-point rounding errors amplify null-state anomalies, and what precise mitigation strategies prevent catastrophic drift in production environments. This article breaks down the mechanics behind zero-angle failures, examines real-world computational vulnerabilities, and lays out concrete protocols to neutralize them.
The Mathematical Foundation and Floating-Point Traps
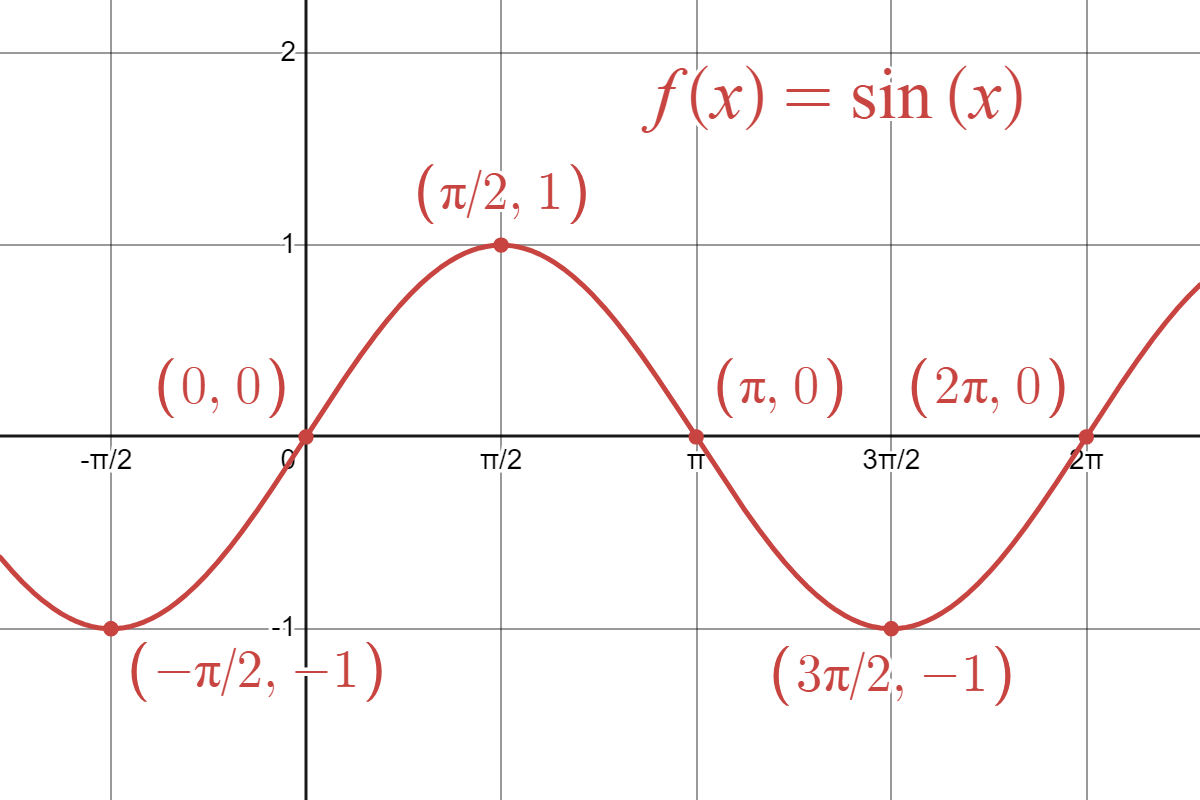
In pure mathematics, the sine of an angle measuring zero radians or degrees equals zero. The unit circle defines sine as the y-coordinate of a point on the circumference; at zero radians, that coordinate rests squarely on the x-axis, resulting in a vertical displacement of zero. Because this identity holds universally across analytical geometry, software developers and hardware designers hardcode or call standard trigonometric libraries assuming absolute precision.
The friction begins where abstract mathematics meets finite digital storage. Computers represent real numbers using IEEE 754 floating-point standards. While exact zeros (0.0) are represented cleanly, computed angles rarely arrive as pristine integers or exact constants. Instead, sensor noise, matrix transformations, and iterative vector normalization produce values like 1.2e-16 or -4.5e-17. More reporting by Bloomberg highlights related views on the subject.
When a system evaluates a trigonometric function on these micro-deviations, the output isn't zero. It's a tiny, non-zero fraction. In isolation, that fraction looks harmless. In iterative control loops executing millions of cycles per second, however, tiny residuals compound. Division by these near-zero values or multiplication across unstable matrices triggers severe overflow exceptions, sudden NaN (Not a Number) propagation, or abrupt NaN-induced thread crashes.
How Zero-Angle Conditions Break Complex Systems
System failures rarely stem from the number zero itself; they stem from null-state assumptions. Engineers build control logic assuming that when a system rests at its home position, neutral axis, or equilibrium point, all related trigonometric force vectors drop out cleanly. When rounding errors leave a residual value behind, the system acts on phantom forces.
Consider three common operational domains where this vulnerability manifests:
- Robotic Kinematics and Inverse Transformations: Robotic joints rely on continuous matrix multiplications involving sine and cosine functions. If a joint rests at its zero-degree calibration mark but reports a floating-point artifact, the kinematic solver computes an imaginary translational force. The motor controller tries to correct this phantom error, introducing physical jitter or violent corrective snapping.
- Aerospace Inertial Navigation: Guidance computers calculate aircraft attitude using quaternion and rotation matrices. During straight-and-level flight, pitch and roll angles hover near zero. If the navigation software fails to clamp near-zero values to exact boundaries, accumulated trigonometric drift fools the autopilot into executing unnecessary micro-corrections, accelerating mechanical wear on flight control surfaces.
- Industrial Process Control Loops: Valve actuators and hydraulic regulators use feedback sensors to maintain zero-flow positions. If the control algorithm multiplies error signals against unfloored sine functions during calibration checks, minor electrical noise near the null threshold gets amplified into erratic valve oscillation.
Real-World Case Studies in Boundary Condition Failures
While high-profile system failures often get summarized by single-word root causes like "unit conversion error" or "sensor drift," underlying mathematical edge cases nearly always amplify the damage.
Take the mechanics behind the Mars Climate Orbiter navigation discrepancy. While famously triggered by a mismatch between metric and imperial units, the downstream software failure persisted because trajectory estimation algorithms trusted incoming floating-point state vectors without clamping edge-case boundaries. When tracking vectors passed through null reference points, unconstrained decimal scaling magnified minor trajectory offsets into catastrophic orbital insertion errors. You can read more about aerospace systems engineering standards through NASA Technical Reports Server.
Similarly, industrial automation archives frequently cite control system lockups caused by division operations where denominators evaluate to computed zeros. When an algorithm divides a vector component by $\sin(\theta)$ during a coordinate transformation frame reset, an unhandled zero-angle input causes an uncatchable floating-point exception. Without explicit zero-guards, the control thread halts, forcing a hard system reboot while machinery is actively running.
Step-by-Step Mitigation Strategies for Engineers
Neutralizing zero-angle vulnerabilities requires defensive programming practices that bridge the gap between theoretical math and imperfect hardware. Here's how to bulletproof your codebase against trigonometric boundary failures:
- Implement Explicit Epsilon Thresholds: Never check if a floating-point angle equals zero using strict equality (
angle == 0.0). Instead, define an acceptable tolerance window (an epsilon, such as1e-9). If the absolute value of the angle falls below this threshold, force the evaluation to exact zero. - Hardcode Known Boundary Outputs: When configuring math utility wrappers, intercept standard library inputs for known exact angles ($0, \frac{\pi}{2}, \pi$, etc.) and return pristine constants (
0.0or1.0) before passing parameters to underlying hardware registers. - Audit Division and Denominator Paths: Before executing any calculation involving division by a trigonometric output, wrap the denominator in a safety check that throws a controlled fallback state rather than allowing a hardware-level crash.
- Enforce Unit Testing for Null States: Build automated test suites that feed extreme boundary inputs—such as
0.0,-0.0,1e-15, and-1e-15—into your kinematic and navigation pipelines. Verify that output vectors remain stable and don't produce runaway amplification.
For further reading on robust software engineering practices and numerical stability guidelines, consult resources provided by the Association for Computing Machinery.
Frequently Asked Questions
Why doesn't standard computer hardware handle sin 0 automatically?
Hardware math co-processors evaluate trigonometric functions using polynomial approximations like Taylor series expansions. While highly optimized, these algorithms compute infinite series up to a precision limit rather than executing pure symbolic math, leaving microscopic rounding residuals on inputs that aren't hardcoded edge cases.
Is sin 0 the only trigonometric value that causes system instability?
No. Values where trigonometric functions cross critical thresholds—such as cosine at ninety degrees or tangents approaching infinity—exhibit similar numerical risks. However, sin 0 represents the most common null-state baseline, making it the most frequent trigger for unexpected system initialization bugs.
How can I test my existing software for floating-point drift?
You can implement fuzz testing by feeding your control algorithms thousands of simulated micro-variations around zero-angle inputs over extended virtual runtime loops, tracking whether cumulative state variables drift away from baseline equilibrium.
What is the best programming pattern to prevent division by zero in trig functions?
Always use a safe division wrapper function that checks if the divisor's absolute value is less than your defined epsilon. If it is, the wrapper returns a predefined safe default value or logs a controlled warning instead of executing the raw instruction.


